Joel Lee
Hello everyone!
I’m an AI Engineer at Rebellions, working on accelerating AI systems for physical robotics on NPU devices. I founded a start-up and created a multimodal AI agent with an emotion-aware dialogue chatbot. Our product has been deployed on hardware robots, iOS and web platforms: DITTO
My research focuses on (1) improving physical reliability through simulation-to-real transfer and (2) enhancing contextual understanding with Foundation models for complex manipulation tasks.
I completed my M.S. in Artificial Intelligence at Korea University under the supervision of Sungjoon Choi. I also worked on reinforcement learning for robot navigation at KAIST MDI Lab.
Research Topic:
- Physics-based Robot Control and Simulation
- Robot Foundation Models (e.g., VLA) & Contact-based RL
- Human-Robot Interaction and Preference Learning
publications
- CLEAR: Capability-Aware Latent Ordering for Adaptive Interaction with Movable ObjectsUnder ReviewAn earlier version will be presented at the CoRL 2026 Workshop (LEAP)
-
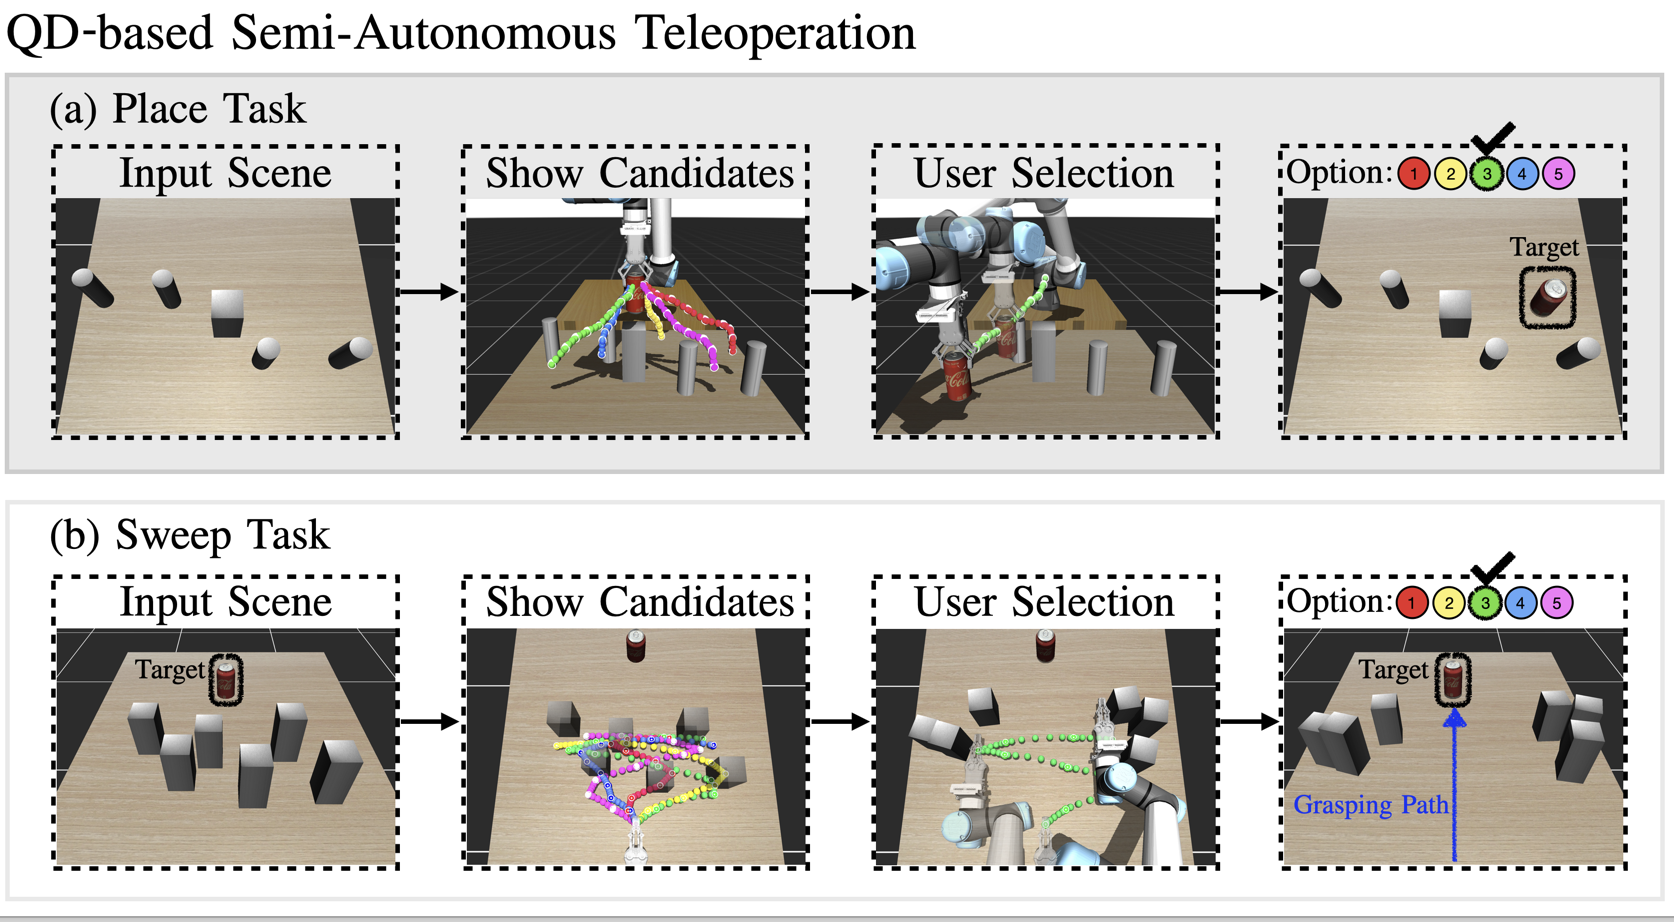 Quality-Diversity based Semi-Autonomous Teleoperation using Reinforcement LearningNeural Networks (IF 7.8 · JCR Top 10% journal in Computer Science, Artificial Intelligence, and Neurosciences.), 2024An earlier version was presented at the ICRA 2025 Workshop (pHRI)
-
 Visual Preference Inference: An Image Sequence-Based Preference Reasoning in Tabletop Object ManipulationIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024An earlier version was presented at the ICRA 2025 Workshop (VLMNM)